Hao Jiang | 姜昊
Dexterous manipulation · Sim-to-real RL · Tactile sensing
I am a second-year PhD student in Computer Science at the University of Southern California, advised by Prof. Daniel Seita. I completed my undergraduate studies at USC, double majoring in Computer Science and Applied & Computational Mathematics.
I work on contact-rich dexterous manipulation and the sensing it requires. I combine learning with model-based structure to make robot hands work reliably in the real world, and I build the systems behind it, from tactile hands to real-to-sim twins.
News
- Oct 2026Released v2 of my open-source LEAP Hand in-hand rotation pipeline: SO(3) reorientation, palm-down fingertip rotation of 22 objects, a measured servo model, and a world-model RL trainer.
- Oct 2026Presented DexMulti at IROS 2026 in Pittsburgh.
- Aug 2026Our USC team was selected as one of four university projects for the Honda Dexterous Hand University Project.
- Aug 2026UniLatent accepted to CoRL 2026.
- Jun 2026DexMulti and HANDFUL accepted to IROS 2026.
- Aug 2025Started my PhD at USC with Prof. Daniel Seita.
Selected Publications
(* indicates equal contribution, † indicates equal advising)
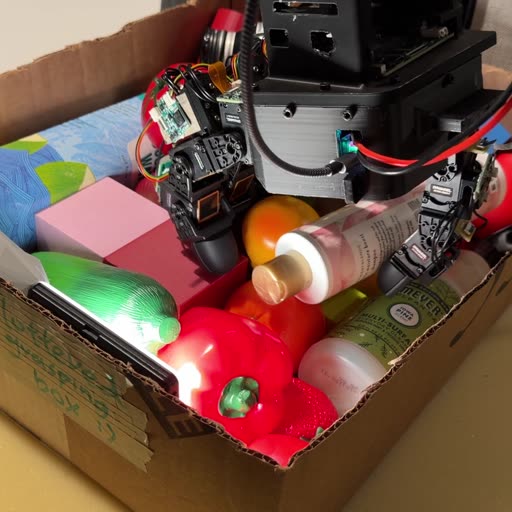
Hao Jiang, , Daniel Seita
In submission, 2026
project page / arXiv
A controlled study of when vision alone stops being enough for dexterous grasping in clutter. Sweeping five scene conditions of increasing occlusion and confinement charts a widening vision–interaction gap, and shows contact wrench and taxel sensing to be complementary rather than redundant.
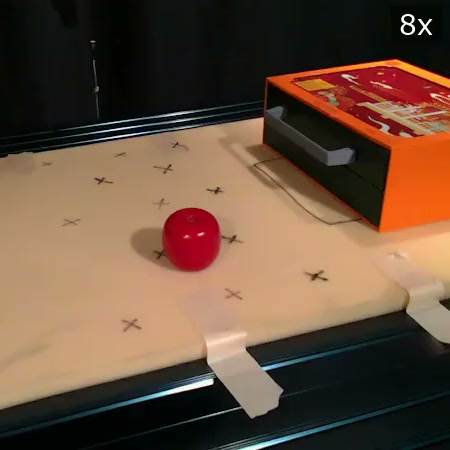
Hao Jiang, , Yue Wang, Gaurav S. Sukhatme, Daniel Seita
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
project page / arXiv / code / datasets
Sample-efficient dexterous manipulation via retrieve-align-execute over object-centric skills. Achieves 66% success on concurrent multi-stage tasks with 3–4 demos per object, outperforming diffusion policy baselines by 2–3×.
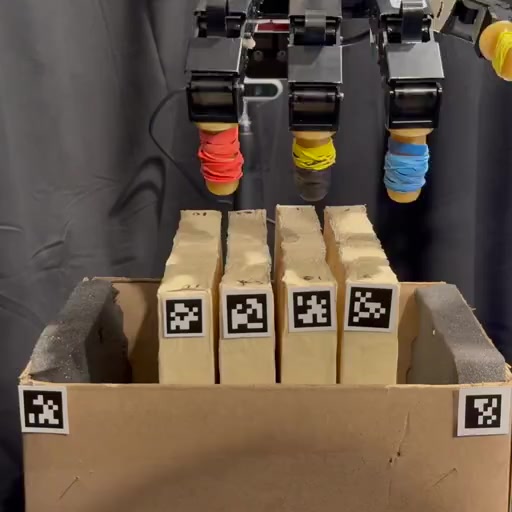
Hao Jiang, Yuhai Wang*, Hanyang Zhou*, Daniel Seita
International Symposium of Robotics Research (ISRR), 2024
project page / arXiv / code / presentation / blog
Multi-phase RL with a displacement-based state representation for singulating target objects in clutter using a 16-DOF Allegro Hand. Demonstrates strong sim-to-real transfer and outperforms baselines in packed-environment tasks.
Other Publications
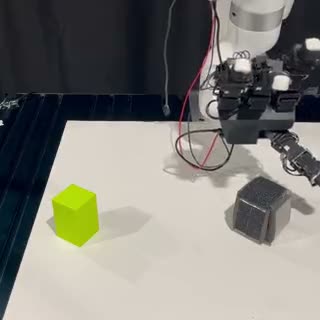
, , Hao Jiang, ,
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
project page / arXiv
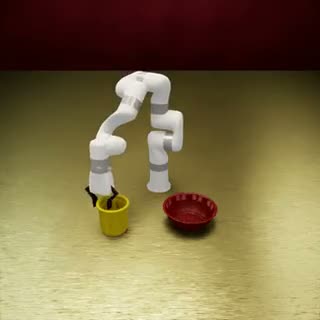
, , , Hao Jiang, , , ,
Conference on Robot Learning (CoRL), 2026
project page / arXiv / OpenReview
, Hao Jiang,
arXiv, 2025
project page / arXiv
Robot Systems
Hardware and software I built and use for the research above. Videos are real robots unless marked as simulation.
Experience
-
Honda Research Institute USAAug 2026Honda Dexterous Hand University Project · USC team (PI: Prof. Daniel Seita)One of four university teams selected nationally. Sequential multi-object grasping: a simulation RL teacher distilled into a point-cloud diffusion policy, with on-site experiments in San Jose, CA.
-
USC SLURM LabSep 2023 – PresentPhD student (2025–) and undergraduate researcher (2023–2025), advised by Prof. Daniel SeitaDexterous manipulation with RL, imitation learning and tactile sensing on Allegro and LEAP hands.
-
QuanMol TechDec 2023 – May 2024Machine Learning Engineer InternContrastive molecule–text models and point-cloud motif–pocket alignment.
Awards
- USC Viterbi School of Engineering Fellowship, 2025–2026
- CRA Outstanding Undergraduate Researcher Award, Honorable Mention, 2025
- USC Viterbi Conference Travel Grant, 2024
- Provost Research Fellowship, USC, 2023–2024
- Academic Achievement Award, USC, 2023
Service & Mentoring
- Conference reviewer: ICRA 2027, IROS 2026
- Journal reviewer: IEEE Robotics and Automation Letters (RA-L), 2025
- Workshop reviewer: Agile Robotics Workshop @ ICRA 2024
- Mentoring: Luis Dominguez (undergraduate, University of New Mexico, 2026); Yue Wu (undergraduate, USC, 2025–2026)
- Course Producer: CSCI 170, CSCI 270 at USC